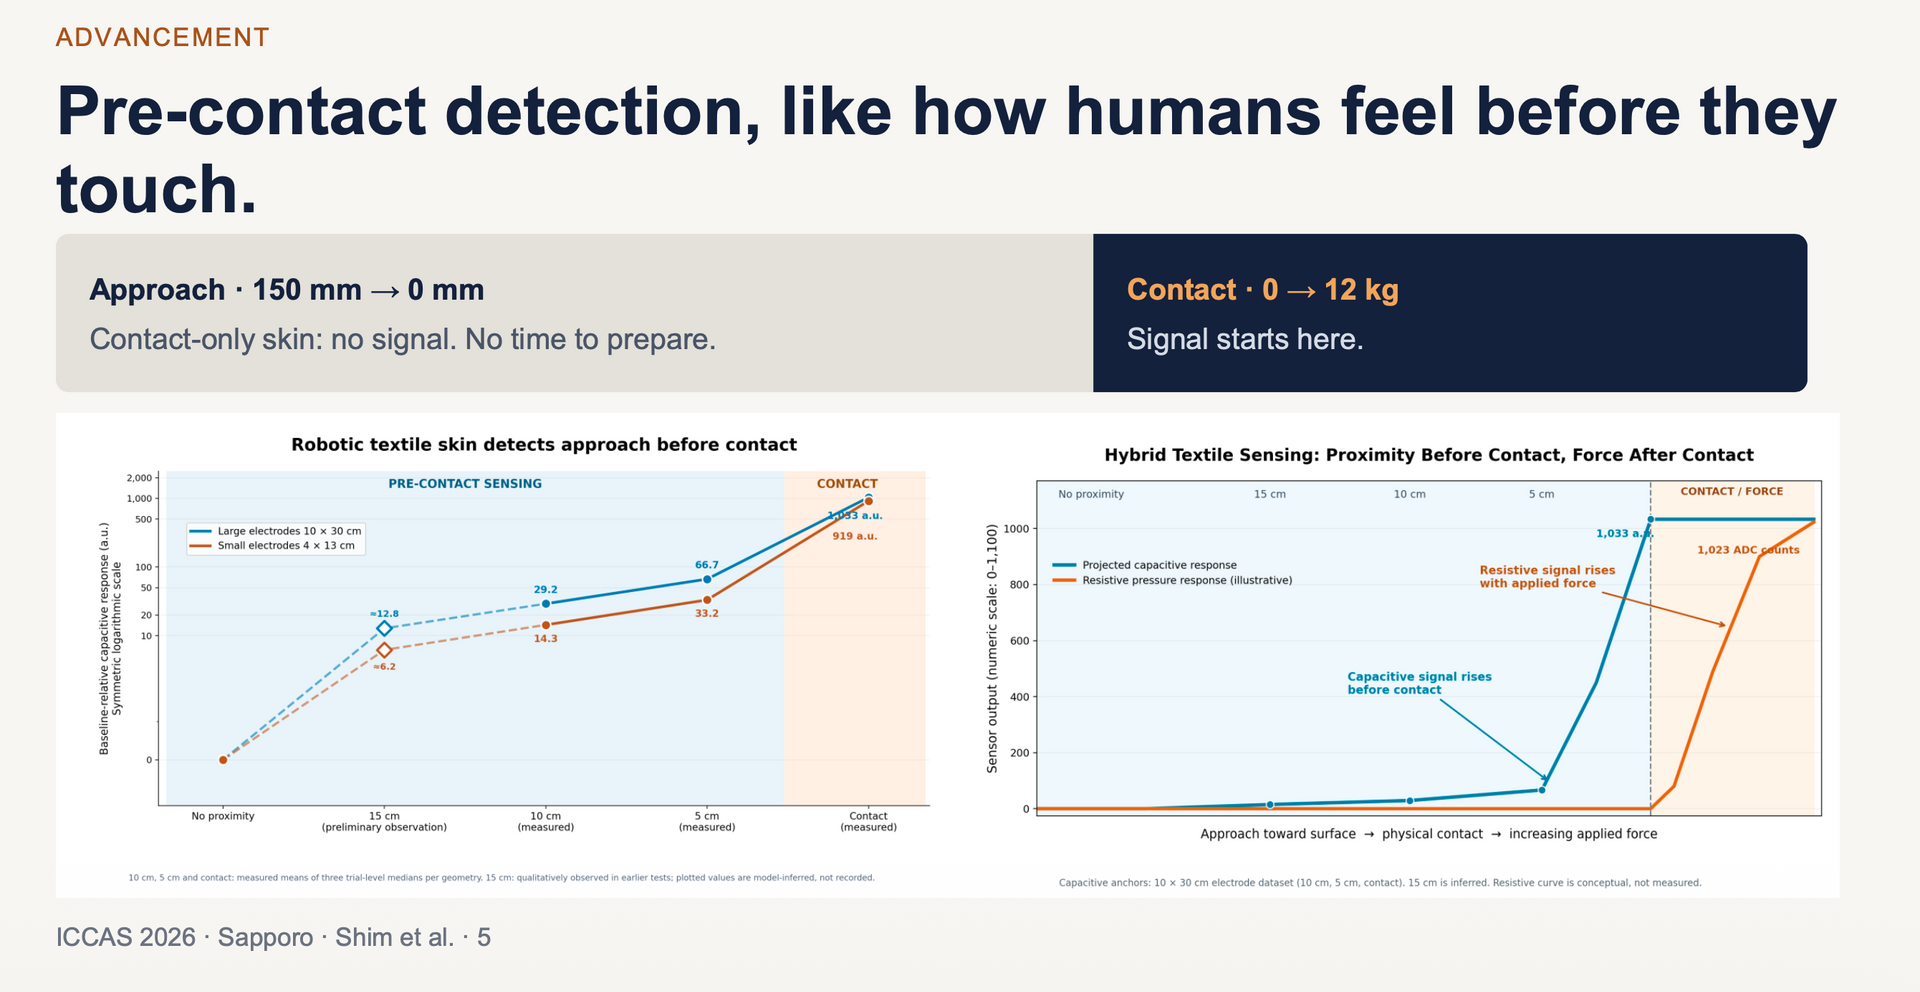
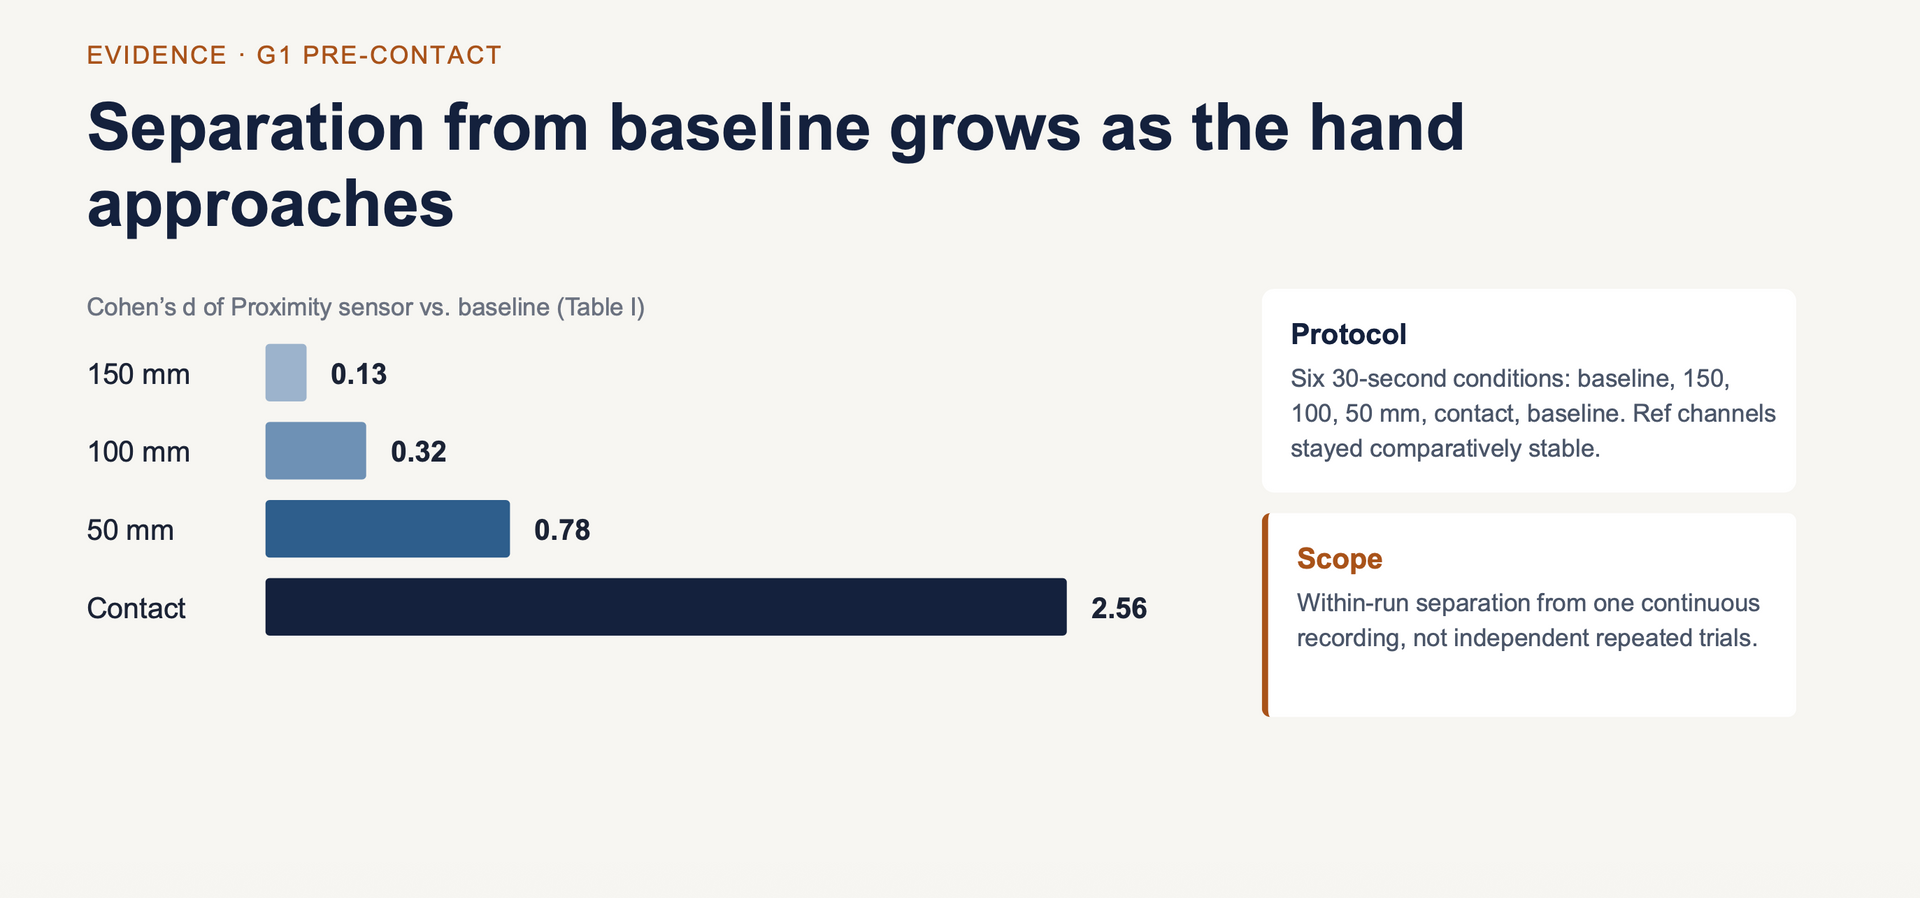
Brighter Signals Presenting new Publication at ICCAS in Japan - Presenting how giving robots the ability to anticipate touch can take them on step closer to understanding how we perceive objects
Edward Shim presents the Brighter Signals paper on Anticipatory Textile-Based Tactile Sensing:Unified Pre-Contact and Contact Response for Embodied Robotic Manipulation at the International Conference on Control, Automations and Systems in Sapporo, Japan


Proud to have presented our peer-reviewed paper as an oral presentation at the 26th International Conference on Control, Automation and Systems (ICCAS 2026): “Anticipatory Textile-Based Tactile Sensing: Unified Pre-Contact and Contact Response for Embodied Robotic Manipulation”.
The core of the work is a textile sensor with a dual-role middle layer that is partially conductive yet dielectric. This lets one structure sense an object in a both modalities of capacitive and resistive sensing in a single unit.
For @Brighter Signals, this milestone isn’t only about interesting technology. Deep tech earns trust when its foundations stand up to independent scrutiny. Peer review gives our work a citable, verifiable basis that the research and engineering community can test, challenge and build on.
This would not have been possible without our funders at Eureka Eurostars and our Dutch national funding agency RVO. Congratulations go to all our authors Edward Shim, Ludo Stellingwerff, Andrew Klein and Christine Fraser. Thank you also must go to our robotics collaborators Seed Robotics and our other funding partners especially Wake Up Capital, ELOKON Ventures, Innovation Fund Noord Holland, Rabobank and Antler.
Thank you for backing the long road from first principles to publication.
Proceedings link to follow once published in IEEE Xplore.
#TactileSensing #Robotics #EmbodiedAI #ETextiles #IEEE #DeepTech